
This article provides an in-depth exploration of hardware design solutions for industrial and service robot control boards, multi-layer PCB layout and signal integrity optimization, as well as high-reliability SMT/DIP assembly and inspection standards.
It also introduces the one-stop PCBA manufacturing services offered by KingTop Technology (Shenzhen KingTop Technology Co., Ltd.).
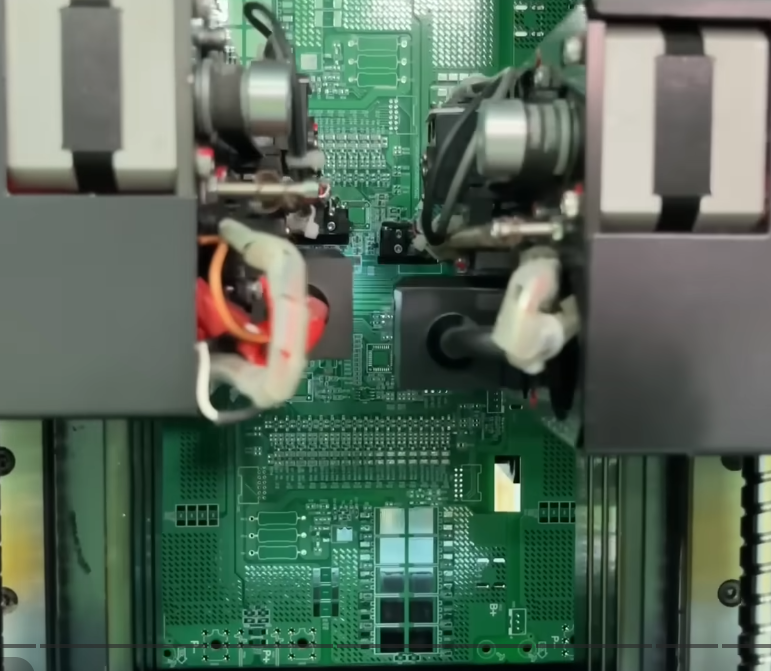
I. The “Central Nervous System” of Robot Control Systems
Amid the current wave of Industry 4.0, intelligent manufacturing, and the rapid growth of the service robotics industry, robots have evolved from simple tools for repetitive mechanical tasks into sophisticated, high-tech equipment that integrates high-precision sensors, complex algorithms, edge computing, and intelligent decision-making capabilities.
Serving as the “brain” and “central nervous system” of a robot, the control board’s performance directly dictates the robot’s motion precision, response speed, stability, and level of intelligence.
Furthermore, as the physical foundation and the core medium for electrical connectivity, the quality of the PCB assembly (PCBA) process is directly linked to the control board’s reliability and operational lifespan—even when subjected to complex or harsh working environments.
This article offers a detailed analysis of core design architectures and key technical challenges for robot control boards, while examining best practices for PCB assembly. Finally, by highlighting the technical and service advantages of an industry leader—KingTop Technology—this guide serves as a comprehensive resource for companies involved in the R&D and manufacturing of robotic hardware and software.
II. Core Architectural Design of Robot Control Board Solutions
Robot control systems typically employ layered, distributed, or centralized software and hardware architectures. An efficient, stable, and highly scalable robot control board solution generally consists of the following core modules:
+-----------------------------------------------------------------+
|                   Robot Master Computing Core                   |
|             (High-Performance MCU / DSP / FPGA / SoC)            |
+--------+------------------+------------------+------------------+
         |                  |                  |
         v                  v                  v
+------------------+ +------------------+ +------------------+
|   Motion Control | | Sensor Interface | | Communication &  |
|      Layer       | |      Layer       | |    Bus Layer     |
|  (PWM, Encoder)  | | (IMU, Vision, IO)| | (EtherCAT, CAN)  |
+------------------+ +------------------+ +------------------+
2.1 Main Control Chip Selection and Computing Architecture
The main control chip serves as the heart of a robot’s control board. Depending on the type of robot, the computing architecture of the control board varies significantly:
Industrial Robots and Multi-Axis Robotic Arms: These typically employ a dual-core architecture—combining a DSP (Digital Signal Processor) with an FPGA (Field-Programmable Gate Array)—or high-performance multi-core processors from the ARM Cortex-R or Cortex-A series.
DSPs excel at high-frequency, complex floating-point mathematical operations (such as PID control algorithms or matrix calculations for forward and inverse kinematics), while FPGAs—leveraging their parallel hardware processing capabilities—are ideally suited for tasks like multi-channel encoder signal acquisition, high-speed multi-axis PWM output, and hardware-level fault protection.
Mobile Robots (AGVs/AMRs) and Service Robots: These systems tend to utilize heterogeneous computing SoCs (such as the NVIDIA Jetson series, Qualcomm embedded platforms, or high-compute ARM chips). By integrating a CPU, GPU, and NPU, these SoCs can simultaneously handle chassis motion control, machine vision, SLAM (Simultaneous Localization and Mapping), and AI-based navigation algorithms.
2.2 Sensor Interfaces and Signal Conditioning Circuits
Robots rely on a diverse array of sensors—their “sensory organs”—to collect data. These include absolute/incremental encoders, IMUs (Inertial Measurement Units), torque sensors, ultrasonic sensors, and infrared anti-drop sensors.
High-Precision Sampling and Isolation: Given the severe electromagnetic interference (EMI) often present in industrial environments, sensor inputs on the control board must incorporate robust isolation—such as opto-isolation, magnetic coupling, or digital isolation.
Signal Conditioning: For weak analog signals (e.g., microvolt-level outputs from strain gauges), precision amplification via low-noise operational amplifiers, filtering, and analog-to-digital conversion (ADC) are required. This ensures that the control algorithms receive clean, accurate environmental data.
2.3 Power Drive and Actuator Interfaces
The movement of a robot’s joints or drive wheels relies on high-power motors, such as BLDCs (Brushless DC motors), PMSMs (Permanent Magnet Synchronous Motors), or stepper motors.
Drive Topology: The control board typically integrates a three-phase full-bridge drive circuit, utilizing MOSFETs or IGBTs as switching components.
Protection Mechanisms: Robust protection features are essential, including Over-Current Protection (OCP), Over-Temperature Protection (OTP), Under-Voltage Lockout (UVLO), and dead-time control, to prevent power components from burning out due to shoot-through or overload conditions.
2.4 Communication Bus Design
Modern robotic systems are highly modular, requiring high-speed, real-time communication between joints, end-effectors, and the main control board.
Industrial Fieldbus: The CAN bus (specifically the CANopen protocol) is widely used for communication within the joints of small-to-medium-sized robots. For industrial robots requiring high real-time performance and multi-axis synchronization, the EtherCAT bus has become the dominant standard; control boards often integrate a dedicated EtherCAT slave controller (such as chips from ASIX or Beckhoff).
General Communication: Depending on the specific application, interfaces such as UART, SPI, I2C, Ethernet, and wireless communication modules (Wi-Fi, Bluetooth, 5G) may be configured.
III. Analysis of Typical Application Scenarios for Robot Control Boards
Different robotic configurations impose distinct requirements on control board designs, necessitating a tailored approach for each specific use case:
3.1 Control Boards for Industrial Multi-Axis Robotic Arms
Core Challenges: Microsecond-level control cycles, extremely high trajectory-tracking precision, and multi-axis synchronization.
Design Features: Utilization of high-frequency DSPs paired with high-capacity FPGAs; multi-channel, high-resolution PWM outputs; support for multi-turn absolute position memory via absolute encoders (with battery-backed power-loss protection); and the use of highly reliable multi-layer PCB layouts to ensure signal integrity at high speeds.
3.2 Control Boards for Mobile Robot (AGV/AMR) Chassis
Core Challenges: Long battery life, high-power output, and the ability to adapt to complex ground environments.
Solution Features: Wide-voltage input design (e.g., 24V–48V DC); integrated dual-channel or four-channel high-power H-bridge DC motor drivers; comprehensive interfaces for Battery Management Systems (BMS) and safety emergency-stop circuits (Safety IO); and integrated interfaces for multi-sensor fusion.
3.3 Control Boards for Collaborative Robots and Humanoid Robots
Core Challenges: Extreme lightweight design, high integration, and modularity of joint units.
Solution Features: Typically utilizes miniaturized, multi-layer Rigid-Flex PCBs or ultra-high-density HDI (High-Density Interconnect) boards. Drive and control circuitry are highly integrated within the confined space of the robot joints, with a strong focus on thermal management (e.g., localized copper pouring, thermal conductive adhesives, and the use of blind and buried vias for heat dissipation).
IV. Key Considerations for High-Standard PCB Layout in Robot Control Boards
Even a perfectly designed schematic can fail if the PCB layout stage is mishandled—potentially leading to poor noise immunity, frequent system freezes, or complete operational failure. Below are the core specifications for PCB design in robot control boards:
4.1 Separation of High-Voltage/High-Power and Low-Voltage Circuits; Grounding Strategy
Clear Partitioning: Digital circuits, analog circuits, and high-power drive circuits must never be intermixed. The control board should be strictly divided into distinct digital, analog, and power-drive zones.
Single-Point Grounding and Partitioning: Analog ground (AGND) and digital ground (DGND) should converge at a single point near the source. High-power ground (PGND) should be routed via separate, thick traces and connected to the main ground plane through a ferrite bead or a single-point connection; this prevents high-current transients from coupling into sensitive digital chips via the ground plane.
4.2 High-Speed Signal and Bus Integrity Design
Differential Pair Alignment: For high-speed differential signals—such as those used in CAN bus, EtherCAT, or USB—impedance must be strictly controlled (e.g., 100Ω or 120Ω differential impedance). Trace widths and spacing must remain consistent, and the use of vias should be minimized.
Ground Guarding and Shielding: Sensitive signal lines—such as clock lines and encoder feedback pulse lines—should be “ground-guarded” (surrounded by ground traces or planes) and kept away from high-power switching power supplies and inductive components to prevent crosstalk.
4.3 Thermal Design and Power Integrity (PI)
Increased Copper Thickness for High Currents: Power output channels (e.g., motor supply lines, VMOT, and GND) typically require increased copper foil thickness (such as 2oz or 3oz copper). Alternatively, techniques such as exposing copper traces for additional solder reinforcement or utilizing arrays of vias can be employed to handle high currents and prevent localized overheating on the PCB.
Decoupling Capacitor Configuration: Ceramic decoupling capacitors (e.g., a combination of 0.1µF and 10µF) should be placed as close as possible to the power pins of each IC. High-frequency filtering capacitors must be positioned immediately adjacent to the chip’s power pins to reduce power supply impedance and suppress high-frequency noise.
V. PCB Assembly (PCBA) Process and Quality Control for Robot Control Boards
Once the control board design is finalized and the Gerber files are generated, the PCB assembly (PCBA) process serves as the critical manufacturing stage that transforms the design blueprints into a stable, physical product. Because robots often operate in environments characterized by vibration, temperature fluctuations, and electromagnetic interference, the quality standards for their PCBA processes are significantly higher than those for standard consumer electronics.
5.1 Surface Mount Technology (SMT) and Component Selection
Miniaturized Component Placement: As robot control boards trend toward miniaturization, there is widespread adoption of passive components in 0402, 0201, or even smaller packages, as well as fine-pitch QFP, BGA, and CSP packages. SMT production lines must be equipped with high-precision, high-speed pick-and-place machines and Automated Optical Inspection (AOI) systems to ensure placement accuracy at the micron level.
Soldering of Through-Hole and Odd-Form Components: Robot control boards frequently incorporate “odd-form” or through-hole components, such as high-power terminal blocks, transformers, electrolytic capacitors, and heat sinks. These components require the use of selective wave soldering or automated robotic insertion equipment for non-standard parts to ensure robust solder joints with sufficient volume.
5.2 Solder Materials and Process Optimization (Solder Paste & Reflow)
Lead-free Compliance and Reliability: In strict adherence to RoHS standards, SAC305 (Sn-Ag-Cu) lead-free solder paste is utilized. For high-reliability industrial robotics, trace elements (such as bismuth or antimony) may be incorporated into the solder alloy to enhance resistance to thermal fatigue.
Reflow Profile Optimization: Robotic control boards often feature thick copper layers and multi-layer structures, resulting in uneven thermal capacity distribution. A custom reflow profile must be developed based on the specific thermal characteristics of the PCB. This ensures adequate preheating, a stable soak zone, and an optimal peak temperature (typically 240°C–245°C), effectively preventing defects such as insufficient soldering, cold joints, bridging, and the “tombstoning” effect.
5.3 Rigorous Testing and Quality Verification System
Following the assembly of high-standard robotic control boards, the products must undergo a stringent, closed-loop testing process before leaving the factory:
SPI (Solder Paste Inspection): Real-time monitoring of solder paste thickness, volume, and area during the printing stage to proactively prevent defects.
AOI (Automated Optical Inspection): Verification of SMT-placed components to ensure correct placement and orientation, while checking for missing parts or reversed polarity.
X-Ray Inspection: Non-destructive imaging of bottom-terminated components—such as BGAs and QFNs—to detect internal voids that could lead to latent failures.
ICT / FCT (In-Circuit Testing / Functional Testing): Utilization of specialized automated test fixtures for robotic control boards. These fixtures simulate actual operating voltages, input encoder signals, and electrical loads to comprehensively verify that motor drive outputs, communication interfaces, and control logic are functioning perfectly.
Conformal Coating: For industrial or outdoor robotic environments characterized by high levels of humidity, dust, or oil contamination, a high-performance conformal coating—typically acrylic, polyurethane, or silicone—must be applied uniformly to the PCBA. This enhances insulation, moisture resistance, and corrosion protection.
VI. Industry Excellence: KingTop Technology – Solutions and Service Advantages
In the complex ecosystem of robotics control board R&D and manufacturing, selecting a partner with extensive experience, robust technical expertise, and a proven track record for quality is critical.
As a global leader in Electronics Manufacturing Services (EMS) and smart hardware solutions, KingTop Technology possesses deep technical expertise and a strong industry reputation in the design and high-precision assembly of robotics control boards.
6.1 Comprehensive Turnkey R&D and Manufacturing Services
KingTop Technology offers a full-spectrum, turnkey service for robotics clients worldwide. This encompasses the entire product lifecycle: from initial concept definition, schematic design, PCB layout, and Design for Manufacturing (DFM) reviews to global component sourcing, SMT/DIP assembly, rigorous testing (AOI, X-Ray, and FCT), and final conformal coating and product assembly. This end-to-end approach significantly shortens product development cycles and reduces the friction costs associated with coordinating multiple vendors.
6.2 Expertise in Complex Board Manufacturing and High-Reliability Processes
High-Precision Manufacturing Capabilities: KingTop Technology operates world-class, high-speed SMT production lines. The company is highly proficient in assembling complex PCBs, including heavy-copper boards (supporting high-current designs of 3oz or more), high-layer-count boards (exceeding 30 layers), HDI (High-Density Interconnect) boards, and rigid-flex PCBs.
Stringent Quality Control Standards: The company strictly adheres to international certifications, including ISO9001 and IATF16949—an automotive-grade quality management system that aligns perfectly with the rigorous standards required for high-end mobile robots and industrial robotic arms. Every robot control board undergoes rigorous multi-dimensional testing—including optical inspection, X-ray analysis, and dynamic functional verification—before leaving the factory, ensuring a defect rate that ranks among the lowest in the industry.
6.3 Robust Supply Chain Resilience and Cost Optimization
In the face of volatility within the global electronic components market, KingTop Technology leverages a strong, high-quality global supply chain and a stringent supplier audit mechanism. The company not only assists clients with component alternatives (via an Approved Vendor List, or AVL) to effectively mitigate the risk of supply shortages, but also utilizes its significant procurement scale to optimize total Bill of Materials (BOM) costs—helping robotic systems stand out in a fiercely competitive market.
VII. Conclusion
The development of robot control board solutions and PCB assembly is a highly systematic, multidisciplinary, and sophisticated engineering endeavor. It integrates embedded software and hardware engineering, power electronics, signal integrity theory, and precision manufacturing processes.
Every fine-tuned parameter and every refined soldering technique directly influences a robot’s safety, stability, and operational efficiency in the real-world physical environment.
Looking ahead, the rapid advancement of humanoid robotics, embodied AI, and industrial automation places increasingly high demands on control boards in terms of integration, computational power, and environmental adaptability.
By collaborating closely with partners like KingTop Technology—who possess robust R&D integration capabilities and world-class PCB assembly expertise—robotics companies can accelerate technological breakthroughs, create superior products with greater market competitiveness, and collectively usher in a new era of intelligent manufacturing.